Monday, July 23, 2012

Lights, Camera, Airboat!


On Friday the 13th, the team was lucky enough to play host to the Science Channel who had taken notice of the work Platypus has been doing and decided to shoot an episode of "Through the Wormhole" on Paul, Platypus and the CRW project.

The Science Channel's show "Through the Wormhole" is narrated by Morgan Freeman and has been on Air since 2010, so the team was very excited to hear the news that Platypus would get to appear in an upcoming episode in the next season. As the day came around the team went out to Panther Hollow equipped with seven working and camera ready boats to do some demonstrations. The demonstrations went well especially the testing of the fail safe in which the boats where all the boats were simultaneously called back to a single point as well as the waypoint testing where the boats were sent in a lawn mower motion. Another improvement was the Led Acid batteries that were used lasted much longer when compared to the previously used Nickel–metal hydride battery.


The day was very successful although we encountered some slight problems with a few of the boats shutting down due to overheating and having some speed issues while instructing boats to avoid obstacles.

In addition to our original boats two out of the seven were part of a newly debuted generation and model of boats that are lighter and have a different shape of hull which produces less drag and cuts through the water more efficiently. 

The team displayed the boats ability to communicate with each other in order to explore large bodies of water as well as all of the basic functions.  The team shared the information and results that had been gathered as well as explaining and the usefulness and meaning of these results so people could obtain insight into how these airboats can be utilized for many different applications. Finally after 8 Hours of filming Paul was exhausted from being interviewed and the team was exhausted from watching him being interviewed.

 
Stay tuned for more blogs soon and,

Watch out for Platypus coming to a TV screen near you next Summer! 


Monday, June 18, 2012

Platypus, Politics, And Perpetual Motion

Although our blog has been quiet the past few months, things here at the CRW project headquarters have been anything but. The team made another trip back to Shelby Fish Farms in Ohio to test a bounded filter we developed to deal with the hysteresis of the dissolved Oxygen sensor and spent countless hours at our local Panther Hollow lake debugging and evaluating the algorithm. The end result was a sampling technique with significantly faster convergence than previously used algorithms when applied with a high hysteresis sensor. Our work on this filter will be presented at the 5th International Conference on Intelligent Robotics and Automation this October.

In other news, the CMU CRW project has officially spun off into a startup company; we are now all employees of Platypus LLC., a company which provides an environmental monitoring service using the CRW platform. Check out our logo below:
Our New Company Logo
You may be wondering why we chose to name ourselves after a egg-laying, duck-billed mammal indigenous to Eastern Australia. Platypus are typically thought of in Australia as an animal composed of odd variety of parts: a duck bill, a mostly marsupial reproductive system with the caveat that it lays eggs, waterproof fur, webbed feet, and even its own venom. As such, it is a difficult animal to categorize for taxonomists. Similarly, it is equally difficult to pin a single classification on the CRW platform; one one hand, it is simply a bunch of phones in floating enclosures serving as a mobile sensor network, yet on the other hand it is a full-fledged autonomous multi-agent system. Throw in the heightened pollution sensitivity of a platypus and the fact that it can sense electric fields with its bill, and it makes for a very appropriate mascot. Stay tuned to the blog for more information about Platypus LLC. and links to our company website once we get it up and running.

As part of our startup efforts, we at Platypus have participated in several events over the past week geared at promoting our company and establishing connections for contracts and collaboration. On Thursday of last week the Secretary of Labor for the United States, Hilda Solis, visited CMU to announce a grant to support local manufacturing. Platypus participated in a showcase of local startup companies where we got the chance to talk to the Secretary and show off our boats. The Secretary was quoted as saying, "There’s so many great applications that I saw demonstrated, whether it’s robotics, health care, education — oh my God. I’m just amazed.” Although she didn't mention us by name, its certain that the CRW platform deserves most of the credit for her amazement.

US Secretary of Labor Visits CMU (Courtesy EssentialPublicRadio.org)

Also last week, Platypus and a contingent from the CMU Robotics Institute headed to the Inpex Invention Convention, the largest invention trade show in America, to present Platypus to the world and further expand our network of customers and collaborators. At the fair we saw many new inventions and products ranging from a system for wireless power transmission using microwaves to robots for investigating gas pipelines. We even met one individual with a solution for perpetual motion. Unfortunately, he was reluctant to reveal the details of the system to us before he patented his device.
Platypus and CMU at the Inpex Invention Convention
Finally, we put together a new video summarizing much of our work so far on the CRW platform:


Lots of things are going on so check back soon for updates. We promise not to wait 3 months for our next post.

Wednesday, March 21, 2012

Dissolved Oxygen Monitoring at Shelby Fish Farm, OH

Last year our team travelled to the Philippines to test the CRW platform in a wide range of realistic flood conditions. During our time there we had to opportunity to deploy on Lake Taal, a volcanic lake home to a large segment of the Philippines aquaculture industry. We learned that the crop of fish had recently been devastated by an unexpected rise in water temperature and subsequent drop in dissolved oxygen content (read more in some of our previous posts). This experience first motivated our investigation into using the CRW platform for distributed monitoring of dissolved oxygen content in bodies of water that are used for aquaculture. Most of the aquaculture industry use aerated ponds where a diffused air system is used to aerate the pond multiple times a day to replenish the oxygen. Farm operators usually take hand measurements at a few edges of the pond and estimate the disolved oxygen in the entire pond. This is highly inaccurate as there is some amount of spatial variation and most of the time operators end up over-aerating the pond. If we can estimate the spatial variation of disolved oxygen in the pond, the operators can more accurately estimate when to aerate and potentially save huge amounts of electricity consumed by the diffused air system.  


Early this year our team headed to Shelby Fish Farm in western Ohio to put the boats to the test and see how well the system could map spatial and temporal variations of dissolved oxygen content in the water. Equipped with the Atlas-Scientific dissolved oxygen sensor, the airboats gathered data autonomously using random, lawnmower, and highest uncertainty sampling patterns. Some of the data gathered is presented below.


Spatial variation of D.O in Shelby Fish Farm,OH

Hysteresis effect observed in 10m X 10m area

Analysis on the data revealed that the sensor suffered from the hysteresis effect in which the sensor responds slower than the rate of change of the variable that is being observed in the field. Spatial measurements obtained using most electrode type sensors exhibit this effect. This effect can be compensated by intelligent sampling techniques that predict the rate of change and take measurements in an adaptive way. It was also observed that some of the data collected was corrupted with a lot of random noise. Further investigation revealed that the noise was introduced into the system due to the mechanical shock caused by the sensors bumping against hulls in the boats' wakes. However in the non-corrupted data, we observed spatial variations in dissolved oxygen throughout the ponds. This suggests a potential opportunity for using the CRW platform to monitor large aquaculture areas to efficiently generate up-to-date maps of dissolved oxygen content and identify areas in need of re-oxygenation. By mounting the sensors rigidly below the waterline, we hope to eliminate the noise caused repeated shocks to the sensor and verify our findings. We will test this theory when we head back to Shelby Fish Farm this weekend to gather more data and test the additional sampling algorithms that we have developed to compensate for the hysteresis effect.

Above is a video of 4 boats autonomously collecting D.O data.


Heres a video below on a manual sampling technique by the State Water Resources Control Board.

Saturday, January 28, 2012

Better late than never

There were two big tests in the last couple of months that kept us too busy to write blog posts.

In November we went out to Gowanus Canal, one of the dirtiest pieces of water you can imagine, right in the heart of Brooklyn (that part you might believe). It was a two day trip, with two objectives. First, we wanted to meet with and integrate the sensor of a New York company called WaterCanary. They are building a pretty cool sensor that will eventually allow real-time, low-cost measurement of a low of stuff about water. Then we wanted to test in the canal to show that water that you can smell from about a kilometer away is actually pretty dirty.

We turned up early (6am!) to do the sensor integration at the WaterCanary offices and hit every possible snag one could hit. Nothing worked. Nothing. An integration that should have taken an hour took six hours. Finally, it worked and we jumped in the cars to head down to the canal (just get to Brooklyn and follow your nose). As we were setting up, a nearby worker warned us it wasn't really safe to be near the water. After that, we let Abhinav put the boat in and out of the water. Naturally, as soon as we were ready to go, it started raining. Hiding under plastic and with the non-waterproof sensor connections wrapped in a shopping bag, we were all set to go when the rain stopped. For just long enough for us to take down the umbrellas and the plastic sheet from over the laptop. Then it started raining again. As long and frustrating as the day had been, we decided to put the boat in anyway. Within 2 minutes the cable connecting the WaterCanary sensor to the boat had got caught in the propeller and had been shredded. It didn't matter anyway, because it was dark and we couldn't see any more.

An image from the boat in the canal, notice the big black clouds in the background.

It has often been said that alcohol fixes all problems. So we went out for a couple of beers, partly to soothe our frustration, but mostly because of the anticipated performance gain. We were trying sufficiently hard that we came last in a pub trivia competition. But it worked.

The next day the rain had gone and we went out again early. This time everything worked perfectly. We collected good data from the electrical conductivity sensor and WaterCanary got good data from their sensor. Here is a plot of the data overlaid on a google maps image:


Our next big test was a high pressure event hosted by the Port of Pittsburgh. The aim was to go down to the point in the center of Pittsburgh and show how we can measure water properties for an audience that included members of the Port of Pittsburgh board, the Army Corps of Engineers and the Coast Guard. Since we had just returned from Gowanas on Tuesday, no one had actually tested in the area of the test until Wednesday and the demo was on Friday. We went down early, set up without incident and decided to tie a safety line on the boat just in case. Lucky we did. It turns out the the current where two major rivers meet to make one even bigger river is too much for our little boats. Although they valiantly struggle across current, when trying to go against current they simply go backwards. Its hard not to feel sorry for them. (This isn't a fundamental problem with the technology, we just need to put on a bigger motor.) So with two days to go before a big demo, we had some pieces of foam that didn't do much more than float (quite fast and noisily) towards the Gulf of Mexico.

This time alcohol was ruled out as a possible solution. Instead we scouted up and down the river looked for a nearby place where the currents were lower. Fortunately, we found such a place not far away where a big concrete area had been built to allow boats to tie up, but more importantly served to create an area without a strong current. If we were able to keep the boats in that area, we could keep them from ending up in Mexico.

The day of the demo started cold, but otherwise absolutely perfect. There wasn't a cloud in the sky and no wind at all. Ducks swam nearby and were oddly unconcerned when we drove a boat through them. Everything went great and the kayaker we got to collect boats on the way to Mexico only had to catch two of the five boats. Photos below:
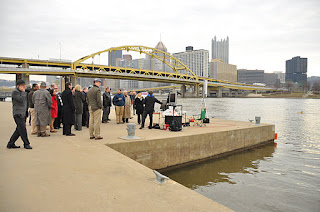


Coming soon: A post about water sampling tests with below freezing temperature water (spoiler alert: Paul was warm in his office, others were not so lucky.)

Tuesday, November 15, 2011

Upcoming demos

The coming few weeks are going to be very exciting for the crw team. We have two big demos coming up. The first one being the Gowanus Canal test on the 29th of November and second being the Port of Pittsburgh demo on the 2nd of December. We will be using our GenX boats with some new state of the art sensors for both of these tests. Our engineers have made some improvements to the communication infrastructure which will enable the boats to travel much farther.

Gowanus Canal, Brooklyn, New York

To those who are not familiar with the infamous Gowanus Canal, here's some history behind it. The canal is located in Brooklyn, New York and was once a major transportation route between Brooklyn and New York City. Due to the discharges from the factories and sewer overflows, the Gowanus Canal has become one of the most contaminated bodies of water in the United States. The Environmental Protection Agency (EPA) has placed the Gowanus Canal in the National Priorities List (NPL) to investigate the sources of contamination. We are planning to deploy our boats to map out the contamination in the canal. In this test, our boats will be equipped with a custom made water sampling system. The boats will also have a specialized water quality sensor that is being developed by our collaborators at Water Canary. We recently bought a few custom made sonars from New Zealand to measure the depth of water bodies. Our engineers are currently working on getting the sonar integrated into our system in time for these tests.

The second test is going to be a big one. We are having a demo for the Port of Pittsburgh to demonstrate the capability of our boats. In this demo we will also be demonstrating a new feature where our boats will detect buoys in the river and verify whether they are at the right location. Buoys are placed in shallow areas of the river to warn barges and cruise boats, however they drift and get displaced. Our boats can potentially be used to verify the buoy's locations and warn the authorities incase their positions need to be readjusted. Yesterday, a couple of us went scouting to find a good place to launch the boats on the day of the demo.


We thought we found the perfect place, until we went closer and found the river bank full of rocks. Although our Chief Deployment Officer wont be present for these tests, our brave and talented shore team will surely manage. On second thought, maybe we will look for a better launch site.


Stay tuned for the first river test sometime this week!

Monday, October 10, 2011

Generation X

Announcing the latest and greatest development in the design and manufacture of autonomous airboats; the new Generation X Autonomous Airboat. Faster, more durable, more maneuverable and more reliable than ever before, it is truly a marvel of modern robotics. 


The all new GenX Airboat
Thanks to the hard work of our engineers back in Pittsburgh, we have successfully redesigned the airboats to address many of the shortcomings we noticed while testing in the Philippines. In just one week after the final design was finished and a prototype was tested, five boats were fabricated and now eagerly await testing.


Boat Rainbow
The new GenX has several great new features we know you will enjoy. First of all, the shroud has been completely redesigned to use a single thickness of extruded acrylic. This helps keep manufacturing costs down and material tolerances at a minimum. The base of the shroud now has additional bolts and a locking spacer ring to keep the bearings within from jamming beneath the top retaining ring.


Permanent Mesh
Furthermore, by popular demand, the mesh on the back of the shroud has become a permanent feature rather than a bolt-on lawsuit deterrent. Using a ring to retain the mesh yields a cleaner design and more sturdily secures the mesh to the shroud, resulting in 80% less finger injuries. Nylon standoffs now replace the custom acrylic spacers use to secure the motor a fixed distance from the shroud. These new components are a cheap piece of commercially available hardware that greatly increases airflow to the motor and decreases the number of components that need to be laser cut.


Motor standoffs - Also available in black!
While the shape of the hull is reminiscent of previous models, don't let that deceive you. The new GenX hull is thinner, sleeker and lighter to provide the smoothest ride possible. At just 4" thick, the hull protrudes from the water significantly less than its predecessors, decreasing the effect wind has on boat motion. The bottom of the hulls has also been covered with a protective rubberized compound to increase durability, particularly during repeated visits to the dry dock for repairs.


Rubberized hull coating
All in all, the new GenX is a true achievement in autonomous airboat technology and a testament to what can be accomplished with an Android phone, an idea and a whole lot of undergrad slave labor.

Tuesday, October 4, 2011

Using a boat in the wake of Pedring

Once the rain stopped and the wind dropped I headed out to find some flood waters. The water levels in the center of Manila, where flooding was once common, dropped within a few hours. Other areas, closer to the bay and with a less advanced drainage system, had knee deep water for days.


Rescue missions mounted across the nation. (Source)
I went to an area called Malabon, that was hit very badly by the typhoon. The streets were covered with debris and knee deep water covered most of the area. After meeting with the Barangay Captain (local councilman) I was given permission to test out the boats. Everyone was very excited and I gathered quite a crowd. Several people lended a hand and we were ready to deploy within minutes.

Setting up the boat
Then... I knocked the wifi router into the flood water!

Without a backup I reluctantly had to cancel the mission. Everyone was very disappointed.

Two days later returned with a brand new router. This time, there was less excitement and my team consisted of only three people. I kept everything inside the car to keep it super dry.

For about half an hour I drove one of the boats around with the sensors attached. The Barangay officials were very amused and advised me that the boat definitely needed reverse (which I agreed with) and a horn (which I am skeptical about).


I will post the results of the testing once the maps are complete.